Recent Articles and Multimedia
Paper Title: How Much Do Your Models Disagree? Adaptive MPC Safety from Ensemble Uncertainty
Author: Ali Baheri
When a controller relies on a learned model of its dynamics, prediction errors are small where the model is accurate and large where it is not, so a fixed safety margin is at once too cautious in some regions and too aggressive in others. This paper introduces Ensemble-Aware Model Predictive Control (EA-MPC), which converts the disagreement among an ensemble of learned models into state-dependent safety margins derived from concentration inequalities.
READ MORE ABOUT THIS PAPER HERE
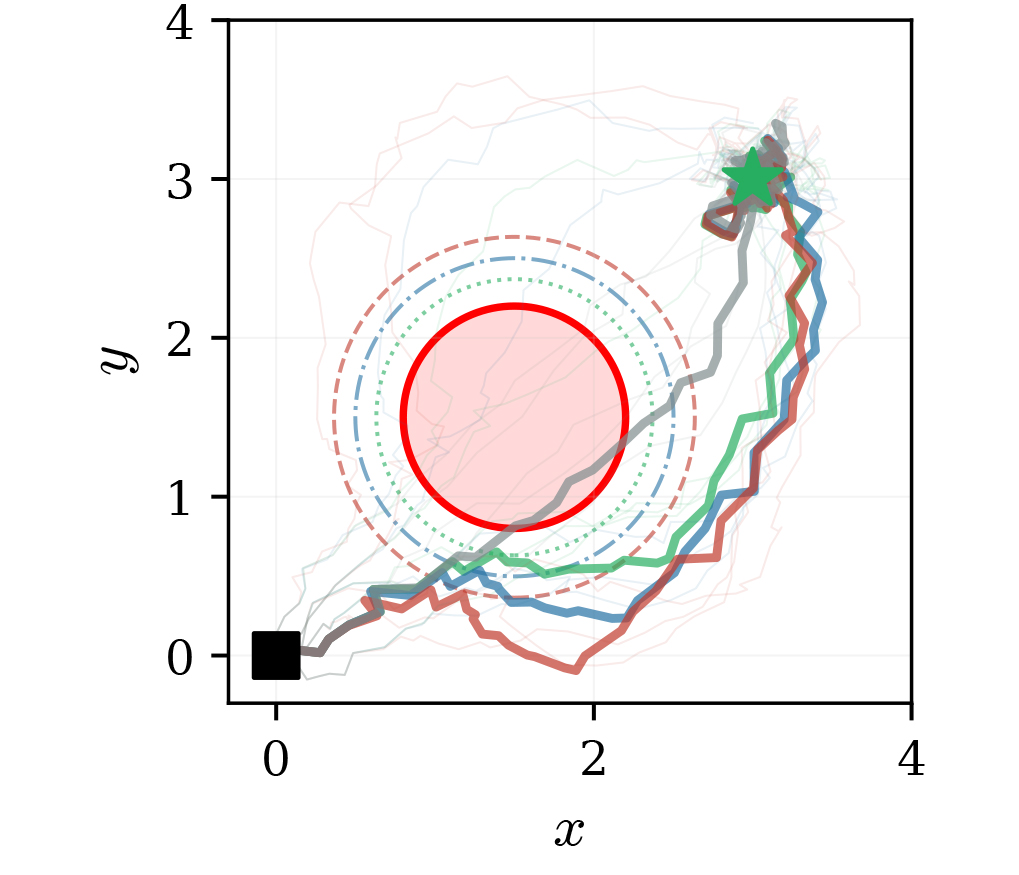
Closed-loop trajectories around an obstacle under EA-MPC. The dashed circles show the inflated safety radius produced by each concentration bound, which widens wherever the model ensemble disagrees.